Director
Director
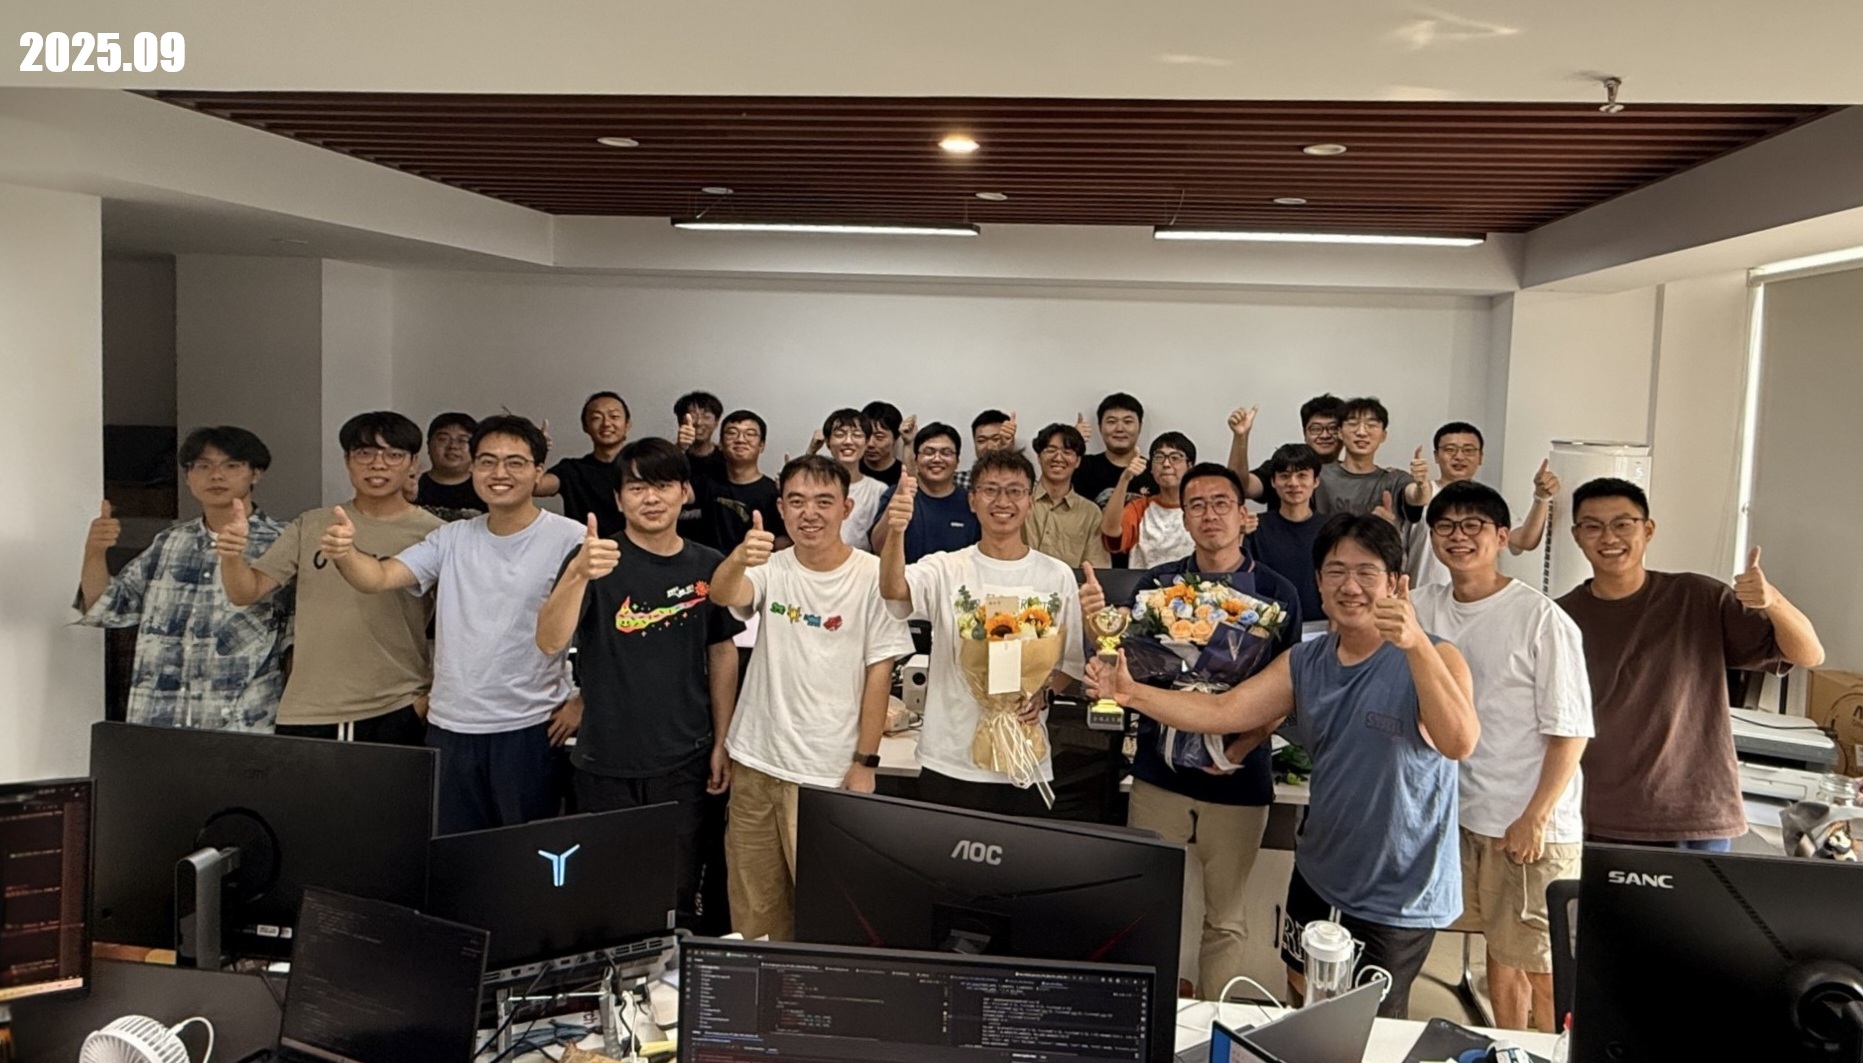
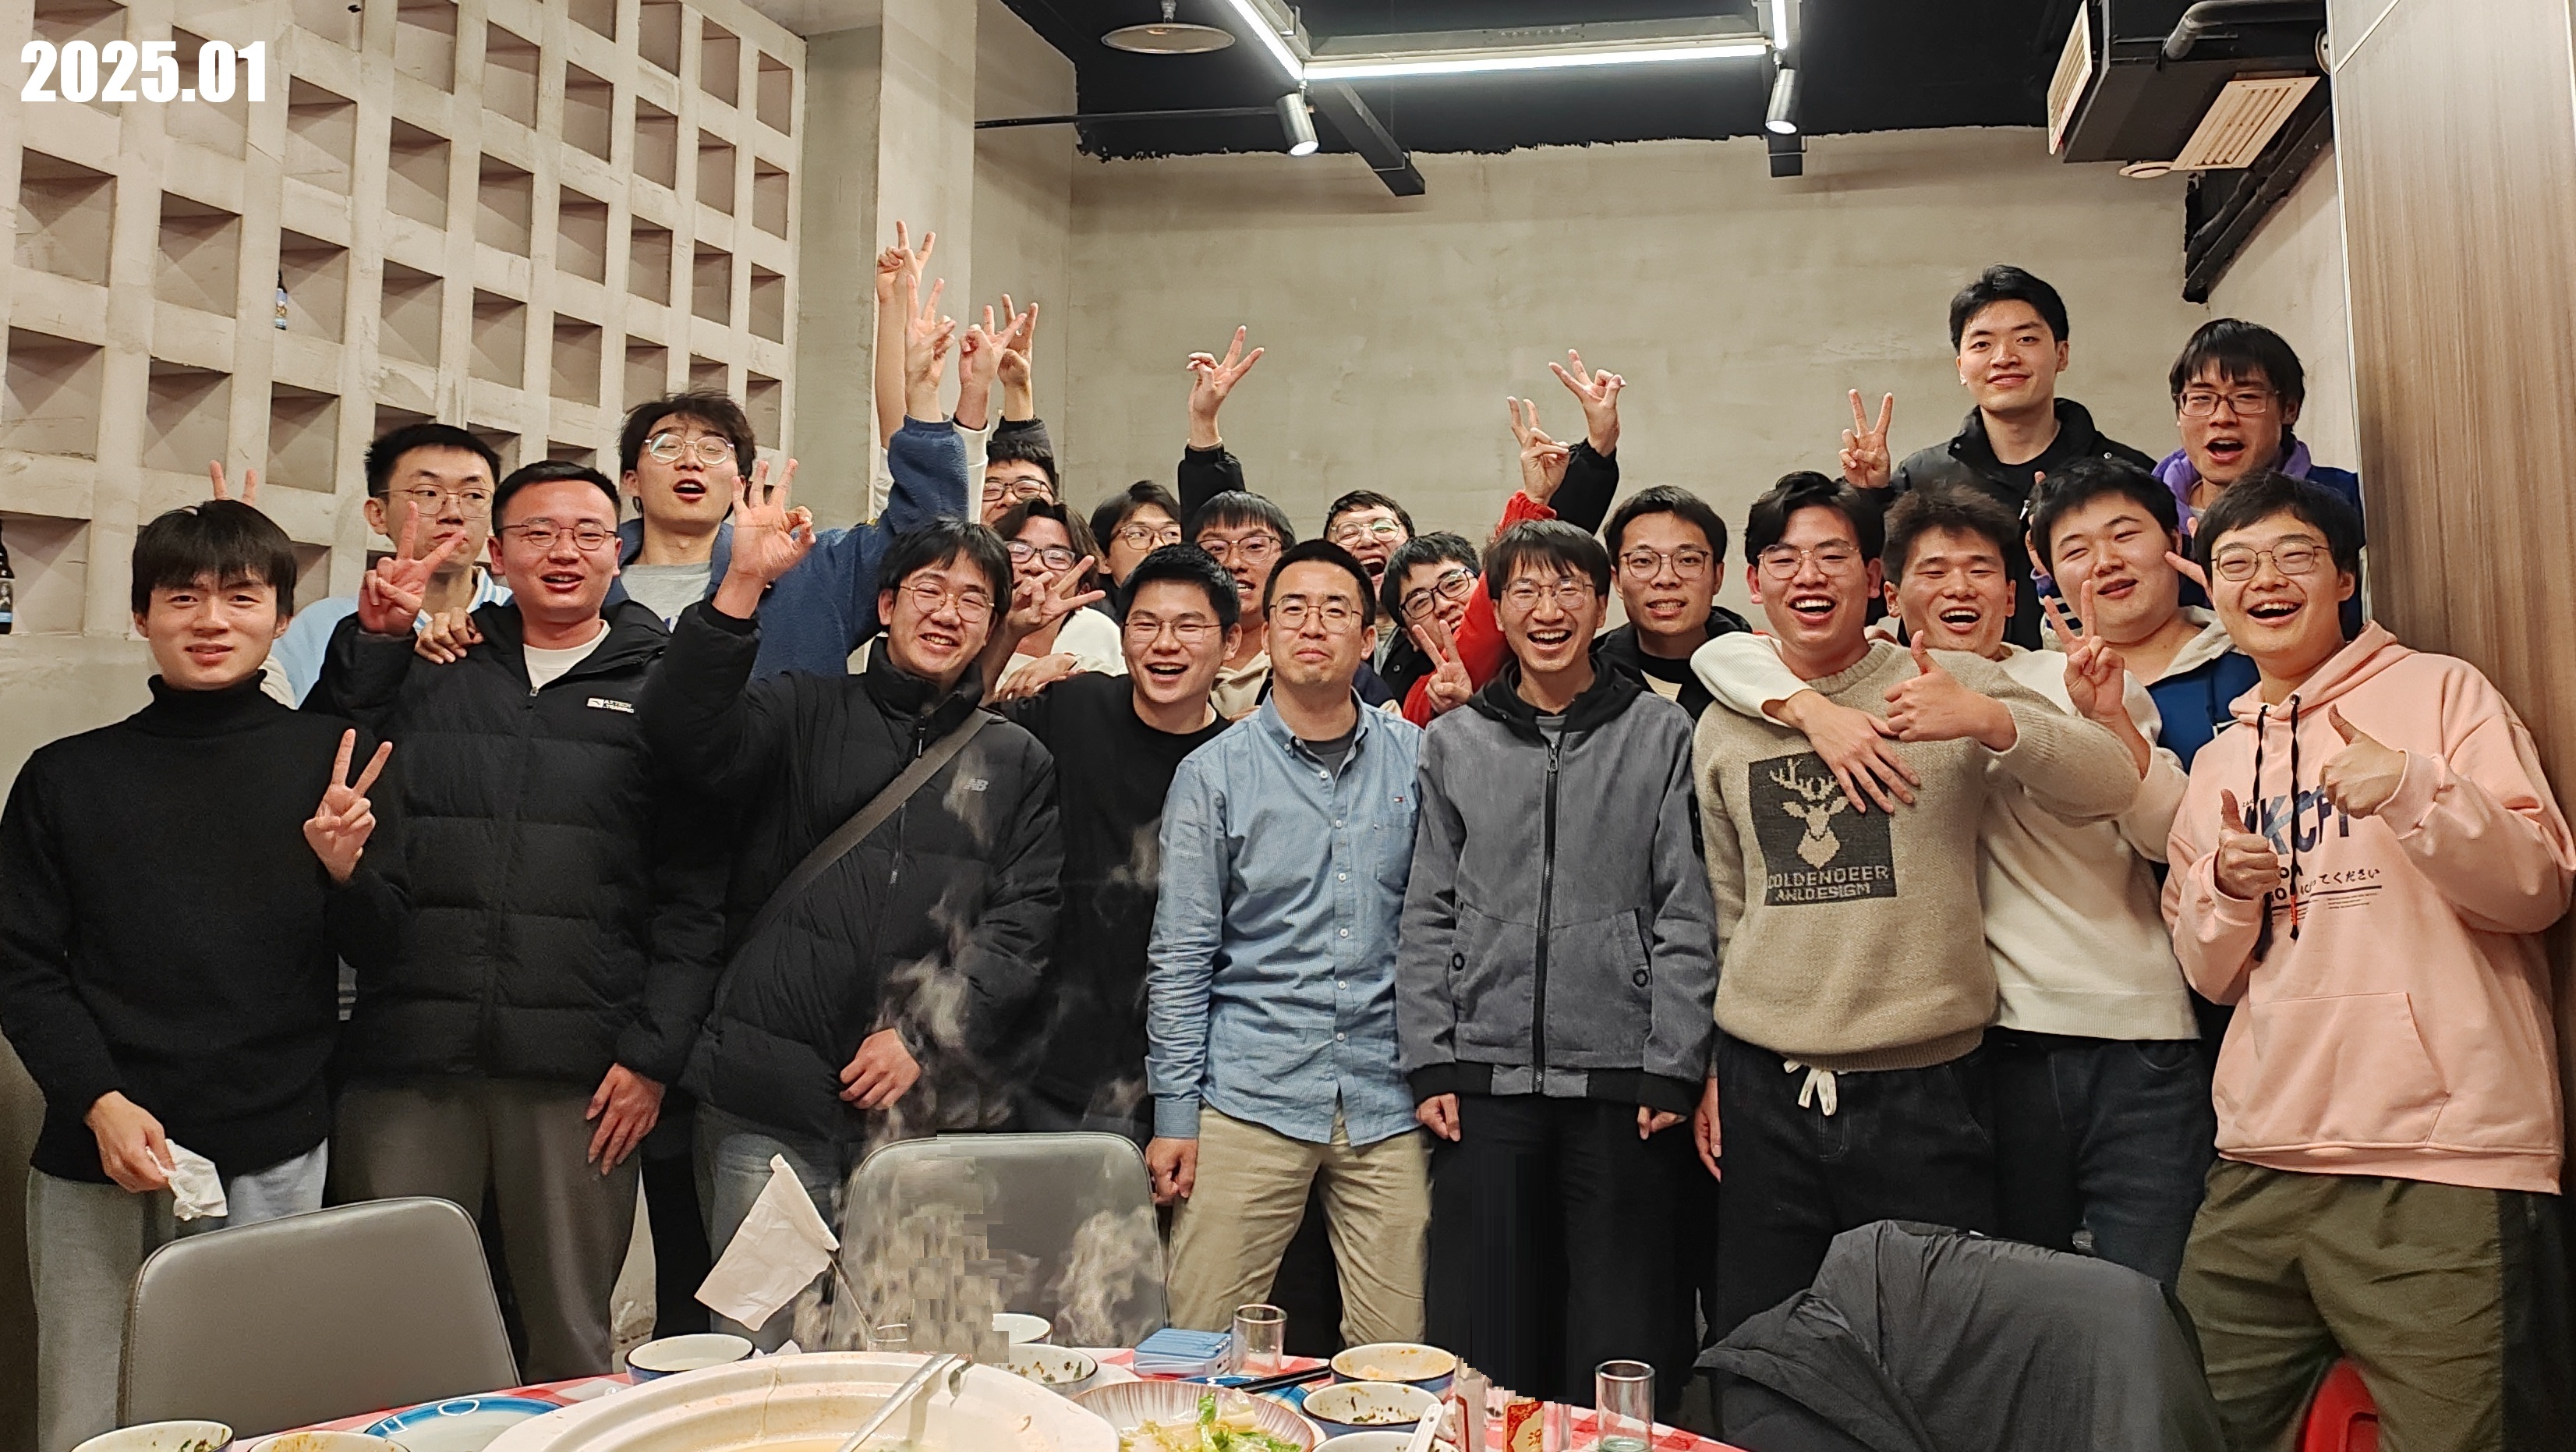
Lab photos
Ph.D. student
Ph.D. student
Ph.D. student
Ph.D. student
Ph.D. student
Ph.D. student
Ph.D. student
Ph.D. student
Ph.D. student
Ph.D. student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Master's student
Tianci Huo
Graduation: June 2026
Employer: Zhejiang Geely Automobile Research Institute Co., Ltd. (Geely Auto Research Institute)
Position: AI Algorithm Researcher
Zhigui Chen
Graduation: June 2026
Employer: Shenzhen Yinwang Intelligent Technology Co., Ltd. (Yinwang)
Position: ADS Algorithm Research and Technology Development Department
Qihong Xue
Graduation: June 2026
Employer: Zhejiang Leapmotor Technology Co., Ltd. (Leapmotor)
Position: Algorithm Engineer
Bo Li
Graduation: June 2026
Employer: Shenzhen Zhuoyu Technology Co., Ltd. (ZYT)
Position: System Safety Engineer
Hai Yu
Graduation: June 2026
Employer: Shenzhen Yinwang Intelligent Technology Co., Ltd. (Yinwang)
Position: AI Algorithm Engineer
Jinyuan Shao
Graduation: June 2026
Employer: Li Auto Inc. (Li Auto)
Position: VLA Inference Acceleration
Keyong Wang
Graduation: June 2026
Employer: Shenzhen Yinwang Intelligent Technology Co., Ltd. (Yinwang)
Position: AI Algorithm Engineer
Qian Hu
Graduation: June 2026
Employer: Chongqing Changxian Intelligent Technology Co., Ltd. (Changxian Intelligent)
Position: Software Test Engineer
About us
10
Ph.D.
10
Joint Ph.D.
41
Master's
41
Joint Master's
2
Staff
8
Former Members
Ph.D. Student
Lu Gan
Doctoral Candidate
Enrolled in September 2023 as a Ph.D. candidate, with a primary research focus on the application of vision-language models in autonomous driving. Currently concentrating on visual scene understanding of complex scenarios in autonomous driving using vision-language models, while also working on the lightweighting of vision-language models/language models. Future plans include exploring multi-agent collaborative decision-making/planning.
Research Interest:
• Vision-Language Models (VLMs)
• Lightweighting / Model Compression
• Multi-Agent Collaborative Decision-Making/Planning
Yuhan Chen
Doctoral Candidate
Vehicle Perception PhD candidate (enrolled in September 2024), TinyML specialist, and embedded AI developer with extensive expertise in lightweight AI model design, development and deployment. Research scope additionally includes novel view synthesis and 4D event analysis.
Research Interest:
• Low-level visual & Mid-level visual image processing
• NVS 3D reconstruction
• Gaussian Splatting
• Hardware PCB product design and manufacturing
More
https://www.zhihu.com/people/qiao-han-80-16
Delin Ouyang
Doctoral Candidate
Delin Ouyang received his bachelor's degree in 2021 and master's degree in 2024 from the College of Mechatronics and Control Engineering at Shenzhen University. He is currently pursuing the Ph.D. degree in College of Mechanical and Vehicle Engineering at Chongqing University, China. His research interests include deep reinforcement learning, planning and control of intelligent vehicles.
Research Interest:
• Autonomous Driving Decision-Making
• Reinforcement Learning-Based Decision Algorithms
Lingfeng Qi
Doctoral Candidate
Research focuses on autonomous driving cooperative perception, specializing in roadside 3D reconstruction, novel view synthesis, and multi-sensor fusion algorithms. Developed vector quantization-based low-bandwidth fusion methods through 3D simulation projects. Future work will advance vehicle-infrastructure perception technologies.
Research Interest:
• Multi-sensor Fusion Perception
• Point Cloud Data Processing
• Roadside 3D Reconstruction
Xiangfei Huang
Doctoral Candidate
The research focuses on dynamic scene reconstruction, with participation in the development of high-fidelity simulation systems for autonomous driving. Future work will explore multimodal sensor data generation for validating perception algorithms and testing end-to-end autonomous driving simulation systems.
Research Interest:
• Dynamic Scene Reconstruction
• End-to-End Simulation Data Generation
Long Cao
Doctoral Candidate
The primary research focus is on scene generation and multi-sensor fusion perception for autonomous driving scenarios. Currently involved in building an intelligent driving simulation platform in the laboratory, specifically responsible for static scene relighting.
Research Interest:
• Multi-sensor Fusion Perception
• Generative Models
• 3D Scene Reconstruction
Kefei Qian
Doctoral Candidate
The main research focus is on autonomous driving scenario simulation, currently working on dynamic and editable related tasks. Doctoral studies are about to commence, with further refinement and expansion of the research direction underway.
Research Interest:
• Image Processing
• Deep Learning
• 3D/4D Reconstruction
• Generative Models
Qiuwei Jian
Doctoral Candidate
His research focuses on environment perception and 3D scene reconstruction for autonomous driving. He currently studies feed-forward 3D Gaussian methods for reconstruction, novel-view synthesis, and algorithm optimization in complex scenes. He plans to integrate these methods with autonomous driving perception to improve 3D perception, reconstruction accuracy, and environment representations in complex dynamic scenes.
Research interests:
• Feed-forward 3D Gaussian Splatting
Shiji Huang
Doctoral Candidate
His research focuses on trajectory prediction (2022–2025) and trajectory planning (2026–present). He has contributed to a project on streamlined route design for real-vehicle testing, developing algorithms that automatically generate test routes and support multiple testing functions.
Research interests:
• Temporal prediction
• End-to-end models
Guanzhong Li
Doctoral Candidate
His research focuses on world models for autonomous driving, and he is currently developing his knowledge in this field.
Research interests:
• Autonomous driving
• World models
Qihong Xue
Doctoral Candidate
Primary research focus is on autonomous driving decision-making and control, currently specializing in large model-empowered single-vehicle intelligence/multi-vehicle collaborative control. During my laboratory tenure, I have participated in multiple projects and gained substantial hands-on experience. Future plans involve exploring various directions in AI4Vehicle.
Research Interest:
• Intelligent Driving Decision-Making
• Large Language Models
• Artificial Intelligence
Bo Li
Master's Candidate
My primary research area is cybersecurity in vehicular networks, with current specialization in identity authentication mechanisms. The objective is to establish a secure and robust vehicular network ecosystem. I welcome collaborations with fellow researchers who share interests in this field for mutual academic advancement.
Research Interest:
• Vehicular Network Security
Jinyuan Shao
Master's Candidate
My primary research interests lie in video object segmentation and acceleration of visual-language large model inference. During my laboratory tenure, I participated in the end-to-end development of industrial software (based on the Qt application framework), implementing parallel execution and interactive optimization for multi-task systems.
Research Interest:
• Video Object Segmentation
• Vision-Language Models
Tianci Huo
Master's Candidate
The primary research focus is on autonomous driving perception, with a current emphasis on compression techniques for VLMs. During the lab tenure, the work involved image processing, VLM perception, and model compression technologies, leading to the development of a multi-network architecture-based strong consistency specular highlight removal algorithm and an N:M sparse structure-based VLM pruning technique. Future plans include exploring the application and deployment of VLMs in vehicle systems.
Research Interest:
• Deep Learning
• Vision-Language Models (VLMs)
• Model Compression
Hai Yu
Master's Candidate
My main research focus is autonomous driving planning, with current work centered on interactive prediction-planning optimization. Future research will explore quantization and deployment of large-scale models.
Research Interest:
• Decision-Making and Planning for Autonomous Driving
Zhigui Chen
Master's Candidate
The main research direction is autonomous driving perception, currently focusing on 3D object detection algorithms that fuse 4D millimeter-wave radar with images.
Research Interest:
• Multi-sensor fusion
Qian Hu
Master's Candidate
My main research focuses on constructing real-world test cases for autonomous vehicles, and I have participated in projects involving test route generation.
Research Interest:
• Autonomous Driving Function Testing
• Autonomous Driving Test Scenario Library Construction
Bingxiang Kang
Master's Candidate
My research is centered around 3D reconstruction, particularly high-fidelity vehicle modeling and dynamic scene reconstruction. In the lab, I've worked on developing collision detection and warning algorithms for robots navigating narrow, reflective spaces. I also built a depth estimation-based algorithm and a software module for loading and visualizing point cloud models. Moving forward, I'm eager to explore new challenges and possibilities in the field of 3D reconstruction.
Research Interest:
• 3D Reconstruction
• SLAM
Tao Jiang
Master's Candidate
Main research focus is on reinforcement learning-based decision-making and control for autonomous driving, currently specializing in multi-agent large-scale model decision-making and control. During the lab research period, participated in a 3D Gaussian-based autonomous driving simulator project, responsible for local Gaussian point cloud editing and deployment.
Research Interest:
• Reinforcement Learning-based Vehicle Decision and Control
Junjie Zhang
Master's Candidate
The current research focuses on multi-sensor fusion-based localization and mapping systems (SLAM), multi-sensor simulation, and LiDAR point cloud processing and registration.
Research Interest:
• Multi-sensor Fusion
• Sensor Simulation
• SLAM
Ke Li
Master's Candidate
During the lab research period, I was primarily engaged in dynamic 3D reconstruction and Unreal Engine 5 plugin development for Gaussian point clouds.
Research Interest:
• Dynamic 3D Reconstruction
Chenfei Guo
Master's Candidate
My primary research area is autonomous driving data synthesis algorithms, with an established pipeline for image data synthesis and ongoing development in trajectory data generation.
Research Interest:
• Data Synthesis
• Trajectory Prediction
• Image Harmonization
Jie Zou
Master's Candidate
My primary research area is autonomous driving scene 3D reconstruction, currently specializing in generative model-based and 3D Gaussian Splatting (3DGS)-enhanced reconstruction. During my laboratory tenure, I contributed to vehicle simulation test scenario construction and developed a dynamic object editing module for autonomous driving scenes.
Research Interest:
• Autonomous Driving Scene 3D Reconstruction
Yingchen Wang
Master's Candidate
The main research focus is on autonomous driving decision-making, currently specializing in reinforcement learning-based decision-making in complex environments.
Research Interest:
• Autonomous Driving Decision-Making
• Diffusion Models
Jun Yan
Master's Candidate
My primary research focuses on decision-making and control for autonomous driving. Currently, I am working on the design of lightweight decision-making models. In the future, I will continue exploring end-to-end model lightweighting techniques and their practical implementation in autonomous driving systems.
Research Interest:
• Autonomous Driving Decision & Control
Funing Cai
Master's Candidate
My primary research area is decision-making for autonomous driving. Currently, I am working on safe reinforcement learning (Safe RL) to achieve high-efficiency decision-making while ensuring safety guarantees. This involves developing algorithms that balance optimal driving performance with rigorous safety constraints in dynamic traffic environments.
Research Interest:
• Reinforcement Learning (RL)
Qi Lan
Master's Candidate
His main research focuses on reinforcement learning, with current specialization in diffusion planning. He plans to further explore applying diffusion models to end-to-end autonomous driving systems in the future.
Research Interest:
• Diffusion Models
Yaohui Ji
Master's Candidate
My research focuses on autonomous driving decision-making, particularly RL and Bézier curve-based trajectory prediction. I developed editable static models in the 3DGS-based UniSim project, with plans for algorithm optimization.
Research Interest:
• RL + Bézier Curves
• Decision-Making And Planning
More
https://blog.csdn.net/2501_91858598
Ying Fang
Master's Candidate
I'm currently fascinated by visual perception, particularly 3D reconstruction and multimodal learning. With solid Python skills, I'm actively studying classic models (e.g., CNN, Transformer) and research papers. I look forward to deepening my theoretical understanding through systematic training in the research group while gradually exploring my specialized focus.
Research Interest:
• Computer Vision
• Motion Planning
Yicui Shi
Master's Candidate
My current research primarily focuses on 3D simulation scene reconstruction. During my time in the lab, I have been actively involved in development work related to simulated environment reconstruction. I intend to further explore this field in the future.
Research Interest:
• 3DGS 3D Reconstruction
• Multi-Sensor Fusion Perception
Shuang Liang
Master's Candidate
My primary research focus is on reinforcement learning (RL). During my undergraduate studies, I participated in a SLAM (Simultaneous Localization and Mapping) project at the lab, where I was responsible for the localization and mapping module. In the future, I plan to explore the intersection of reinforcement learning and path planning, along with related research directions.
Research Interest:
• Reinforcement Learning
• Path Planning
• Decision-Making and Control
Yucheng Pan
Master's Candidate
As a member of the Dynamic Reconstruction team, I participated in a UE5-based dynamic reconstruction project, where I was primarily responsible for developing the main interface UI, functional UIs for various features, and interactive bubble UIs with click-based interactions.
Research Interest:
• Dynamic Scene Reconstruction
• Point Cloud Processing
Yi Zhou
Master's Candidate
My research primarily focuses on the decision-making module of autonomous driving systems, specifically investigating how robust reinforcement learning can enhance an agent's decision-making capabilities in complex, uncertain environments. I am dedicated to exploring robustness optimization of reinforcement learning algorithms in dynamic and adversarial scenarios.
Research Interest:
• Robust Reinforcement Learning
More
https://www.xiaohongshu.com/user/profile/6800d80d000000000403b175
Yu Shen
Master's Candidate
My primary research focus lies in world models, where I'm actively exploring their integration with robust reinforcement learning (RRL). I aim to make continuous advancements in these cutting-edge AI domains and contribute meaningful research outcomes.
Research Interest:
• World Models
• Robust RL
Chen Yang
Master's Candidate
My current research focuses on large language models (LLMs) for autonomous driving applications, with particular emphasis on vision-language models (VLMs) for scene understanding. In the future, I plan to explore multimodal large models and lightweighting techniques for large models to enhance their practicality in real-world autonomous systems.
Research Interest:
• End-to-End Foundation Models
• Edge AI
• Reinforcement Learning
Rende Chen
Master's Candidate
My primary research focuses on reinforcement learning (RL) for decision-making. During my laboratory tenure, I contributed to the UniSim project by developing its dynamically editable modules. I plan to further explore RL applications in autonomous driving decision systems, particularly for complex urban scenarios.
Research Interest:
• Reinforcement Learning Decision-Making
Wenxuan Yu
Master's Candidate
The field I'm most interested in is computer vision, and I'm currently at the learning stage of 3D point cloud object detection and segmentation algorithms. I hope to continuously improve myself during future learning and exploration.
Research Interest:
• Computer Vision
• Point Cloud Data Processing
Yuhao Wei
Master's Candidate
My primary research focuses on decision-making and motion planning for autonomous vehicles, with current emphasis on learning-based end-to-end algorithms. In the future, I plan to explore applications of multimodal large models, diffusion models, and Mixture-of-Experts (MoE) architectures in autonomous driving systems.
Research Interest:
• End-to-End Autonomous Driving Systems
• Reinforcement Learning
• VLM/VLA
Zhongquan Wang
Master's Candidate
2021.9-2024.6, Chongqing University of Posts and Telecommunications, Undergraduate, IoT Engineering
2024.9-2025.6, Chongqing University National Excellent Engineer College, Exchange Student, Intelligent Connected Vehicle
2025.9- , Chongqing University , Master's Student, Robotics Engineering
Research Interest:
• Intelligent Connected Vehicles
• Some interesting things
More
https://blog.csdn.net/Akaxi1 https://akaxi6.github.io/
Yuzhou Chen
Master's Candidate
His research focuses on scene reconstruction from novel viewpoints, particularly 3D reconstruction and novel-view synthesis of autonomous driving street scenes. He studies 3D Gaussian Splatting and NeRF representations, dynamic scene modeling, geometric consistency, and reconstruction quality.
Research interests:
• Scene reconstruction from novel viewpoints
Yining Tang
Master's Candidate
His research focuses on guiding diffusion models to generate safety-critical traffic scenarios. He is currently designing and optimizing guided diffusion algorithms.
Research interests:
• Diffusion models
• Reinforcement learning
Qijie Zhou
Master's Candidate
His research focuses on decision-making and planning for autonomous driving, including deep reinforcement learning, diffusion models, and end-to-end driving systems. He studies decision-making and control in complex traffic scenarios and explores driving decision methods that combine generative models with reinforcement learning.
Research interests:
• Autonomous driving decision-making
• Reinforcement learning
More
https://www.zhihu.com/people/huang-chou-qing-zhuo
Ziheng Zou
Master's Candidate
His research focuses on vision-language-action models and world action models for autonomous driving, particularly world representations for driving decisions. His undergraduate thesis explored vision-language-model-assisted driving decision systems. He is currently working on interpretable intelligent driving decision systems using large models.
Research interests:
• VLM / VLA / WAM
Ze Xu
Master's Candidate
His research focuses on VLMs for intelligent driving, particularly the application of VLM/VLA and end-to-end models to autonomous driving. He plans to explore world-model-supported closed-loop reinforcement learning and cross-domain transfer in embodied intelligence.
Research interests:
• VLM / VLA
• End-to-end models
Guanzhi Xiong
Master's Candidate
His research focuses on combining VLA models with world models for autonomous driving. He aims to build systems that understand multimodal scenes, anticipate future changes, and generate safe driving actions. He plans to study world-model-based simulation, closed-loop evaluation, and robust policy learning to transfer VLA agents from simulation to real roads.
Research interests:
• World models
• Vision-language models
Senlei Ma
Master's Candidate
Senlei Ma received his bachelor's degree from the School of Automotive and Traffic Engineering at Jiangsu University in 2026. He is currently pursuing a master's degree at the College of Mechanical and Vehicle Engineering, Chongqing University. His research interests include autonomous driving scene reconstruction and novel-view reconstruction and restoration.
Research interests:
• Autonomous driving scene reconstruction
Yitian Li
Master's Candidate
His research focuses on decision-making and planning for intelligent driving. He studies vehicle motion prediction using physical models and residual networks, safety-constrained reinforcement learning for decision-making, and multi-step trajectory planning. His work emphasizes driving safety, decision performance, and inference efficiency. He plans to further explore world models for intelligent driving.
Research interests:
• Reinforcement learning
• World models
• Intelligent driving decision-making and planning
Yuanwei Deng
Master's Candidate
His research focuses on 3D Gaussian Splatting scene reconstruction and world models, particularly dynamic scene modeling, novel-view generation, and closed-loop simulation for autonomous driving.
Research interests:
• 3D Gaussian Splatting scene reconstruction
• World models
Peijia Xie
Master's Candidate
His research focuses on scene reconstruction and novel-view synthesis using 3D Gaussians, with an emphasis on optimizing surface reconstruction for street scenes and related assets.
Research interests:
• Street-scene surface reconstruction
Xipeng Feng
Master's Candidate
His research focuses on feed-forward 3D Gaussian Splatting scene reconstruction, particularly novel-view rendering and future scene prediction. He plans to explore end-to-end autonomous driving.
Research interests:
• Feed-forward 3D Gaussian Splatting scene reconstruction
Yangping Quan
Master's Candidate
His research focuses on world models and 3D Gaussian Splatting, particularly 3D reconstruction for autonomous driving scenes. He plans to integrate world models with explicit 3D representations to improve modeling, prediction, and interaction in complex dynamic scenes.
Research interests:
• World models
• 3D Gaussian Splatting
Teaching Building 7, Zone A, No. 174 Shazheng Street, Shapingba District, Chongqing, China, 400030| Phone: 12345678 | Email: 12345678@123.com
Copyright © 2026 Automotive Intelligence Lab